u/Bornity
Bornity
Bornity
I sleep in Shokz bone conducting headphones. If the background noise is too much I put in foam ear plugs. That might be what you are looking for.
Bornity
That's oak right? Someone saw white oak glued up and doubted the strength? Did they think it was cheap pine or something?!
Bornity
Bunch of us here at Old Dominion University are very excited about the potential. We didn't get rid of our smaller tunnel when a lot of other institutions did.
We already have a bunch of ideas we are working on and we're a bit giddy at the fact we have the resources to test and validate designs here.
Feel free to reach out to me if you have something you'd like tested.
Bornity
That's an EA-6A, was that kit bashed or as stock?
Bornity
Yeah, I made gross oversimplifications to describe the concept.
For stable flight the vehicle is continuously adjusting, I think Michel van Biezen has one of the best series in understanding the EKF: https://youtu.be/CaCcOwJPytQ
Bornity
I'm working on a masters in control theory related to mutirotors, so I'm pretty stuck in the weeds with this, It's not an easy problem, but very interesting!
Without additional sensors/measurements you will always see drift, no matter how accurate the gyro/accerometer and get the accumulated error over time. ArduCopter uses the Cube Orange which has 3 IMUs, 2 are temperature controlled vibration damped, while one is fixed in the base. By comparing the fixed with the floating IMUs, frame vibrations can be identified, isolated and compensated for.
The Extended Kalman Filter is currently the most used way to estimate reliability of measurements and then determine states of the vehicle.
One of the things you can do is use the accelerometer measuments, based expected response for a given output of the motors to reset the gyro drift. If you are hovering in a windless environment and all 4 motors are receiving the same PWM signal and you don't see x & y accelerations you can infer there is no rotational motion of the vehicle. By estimating the expected state(s) compared with the observed state(s) you can continuously update the flight solution and prevent drift (within reason).
Hopefully that helps!
Bornity
Check out the Rekon35.
Bornity
Check out the Alva: https://www.printables.com/model/310724-alva
Bornity
Absolutely nailed it. Add in an ADIS-164xx as one of the IMU and you have something sick
Bornity
So sick!
What are you using for video feed and transmitter?
Bornity
Honestly, if you have to ask, buy a ready to fly or build something from a guide.
There are a lot of cool stuff to explore still but actually proving they work aerodynamically is non-trivial.
Bornity
Look up controls engineering
Bornity
Last time I messed with crossfire I had to update the RX, I eventually was able to see the connection on the desktop app. Maybe this will help?
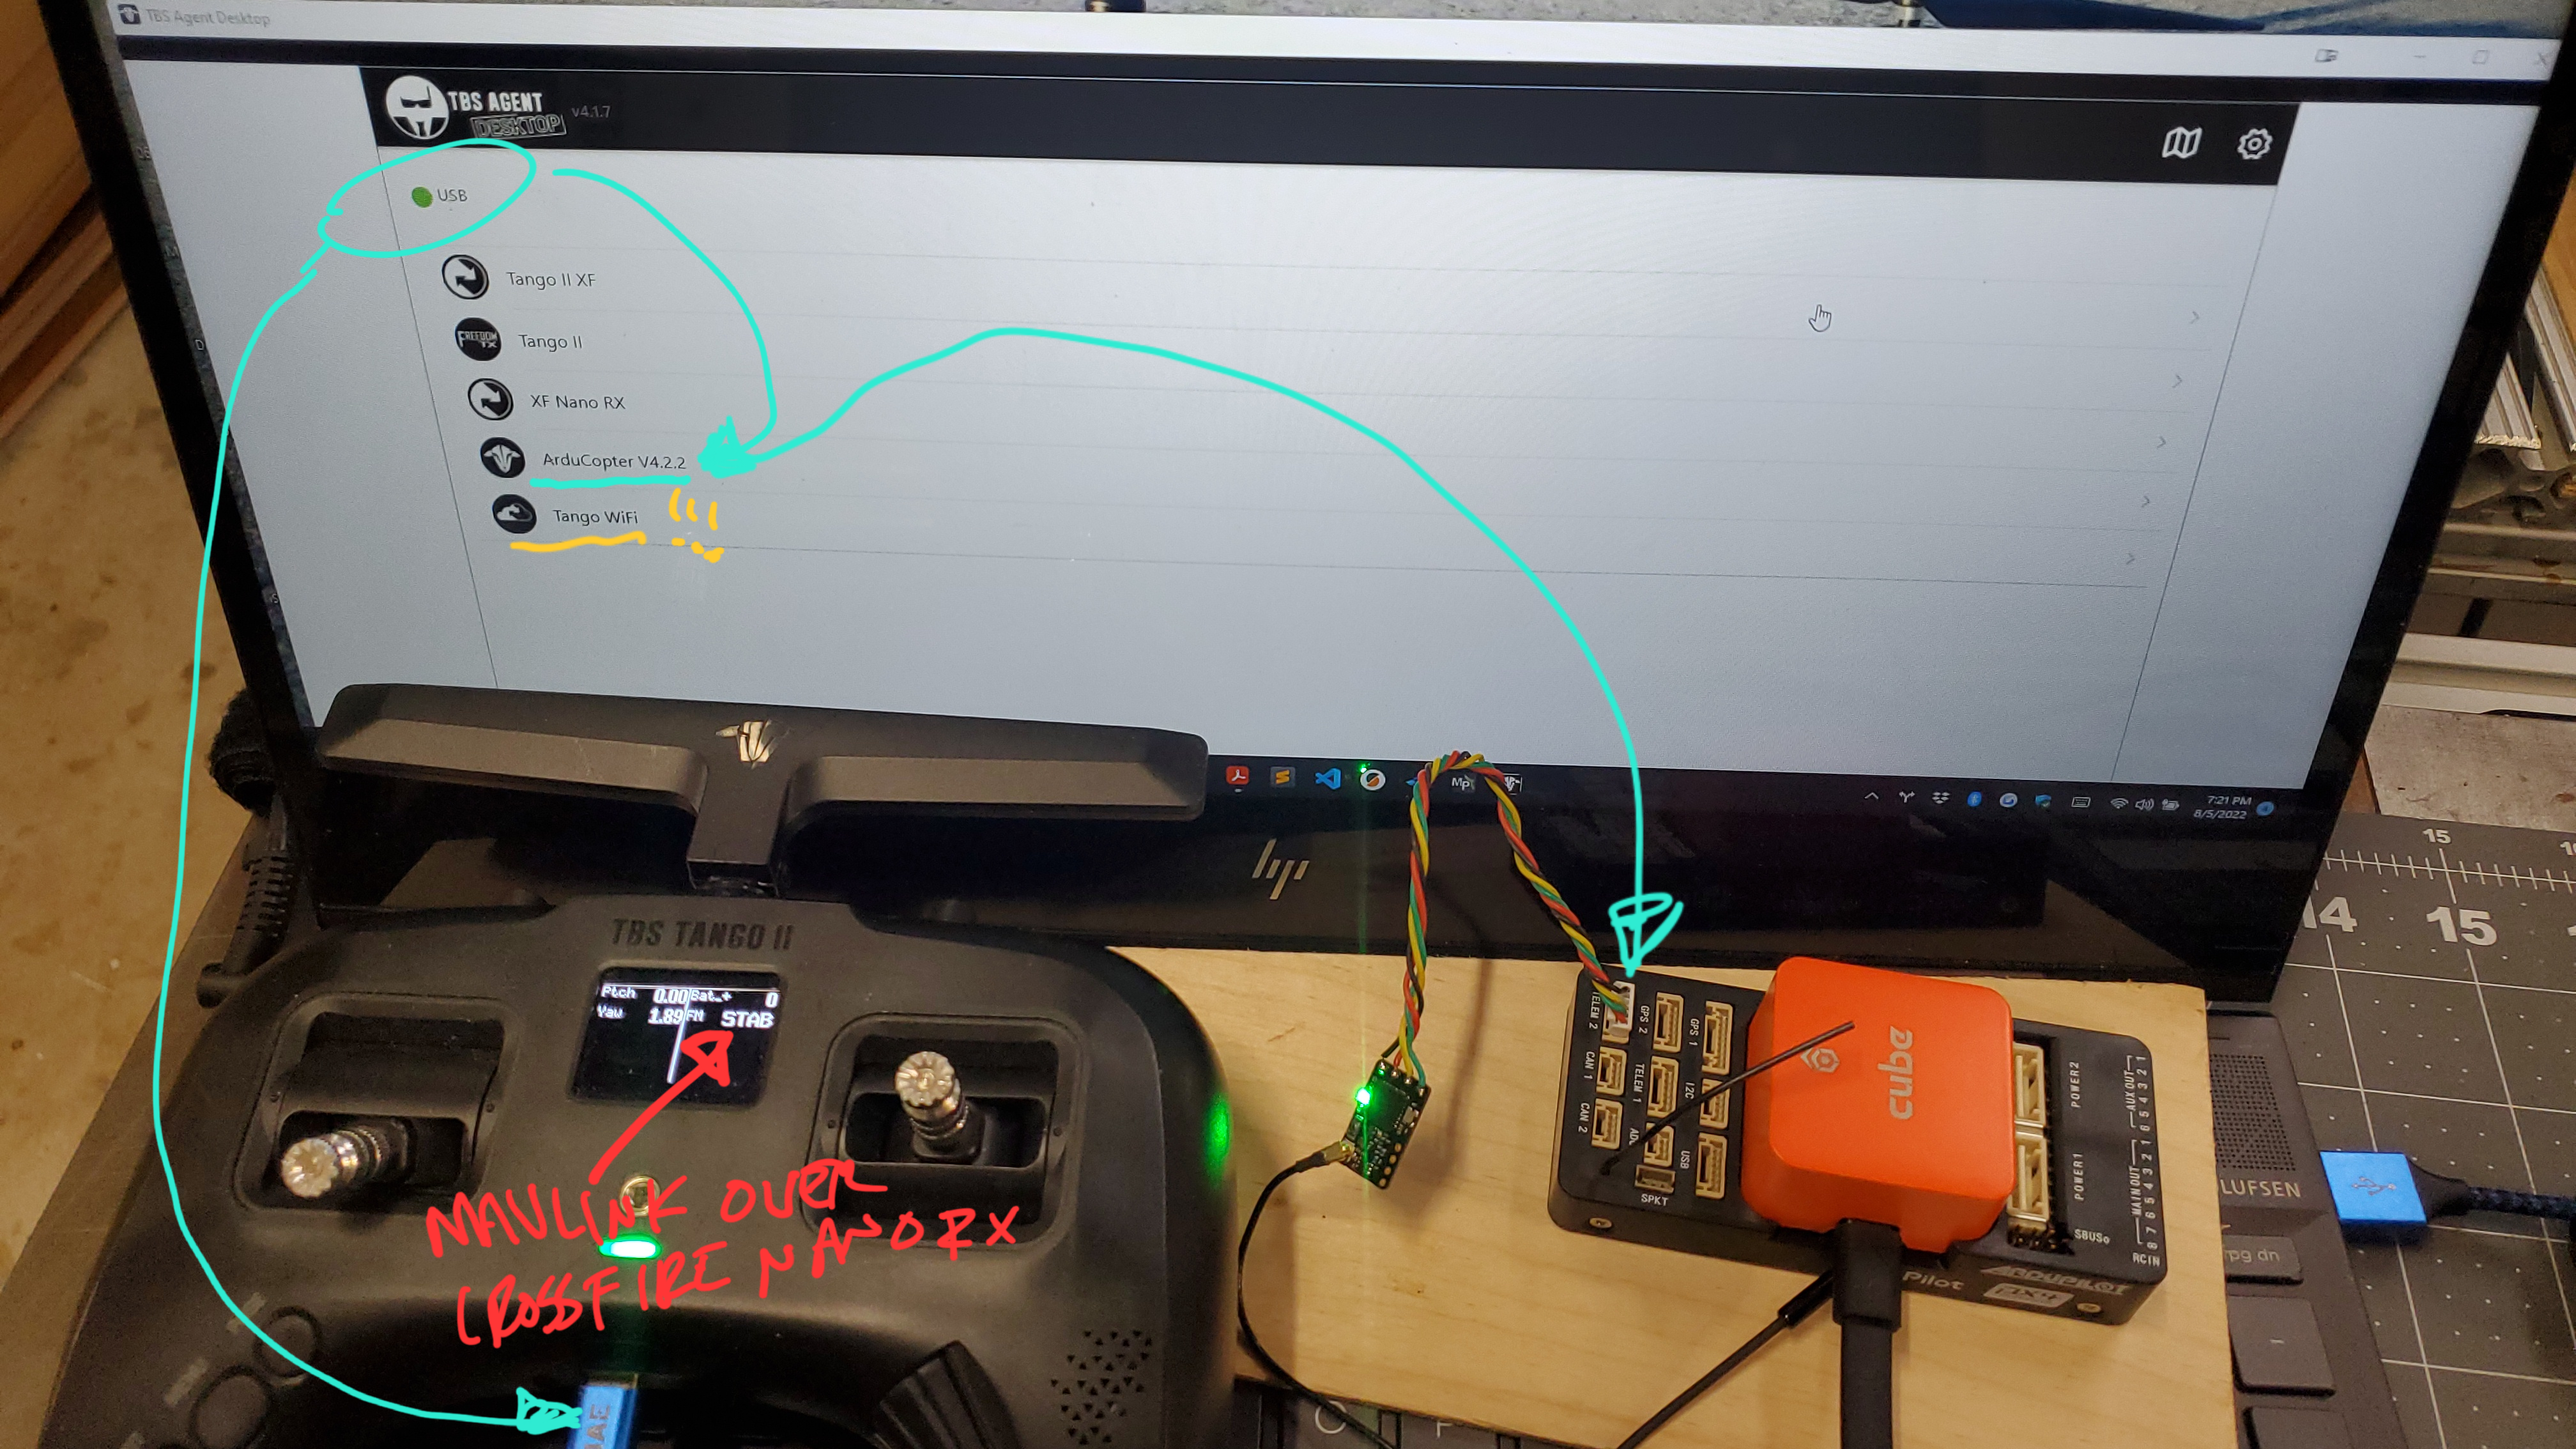
Bornity
Then print an ALVA and follow the guide: https://www.printables.com/model/310724-alva
There is a PDF with instructions under the "Files" tab which is easy to miss
Bornity
Look up RTF(Ready to Fly)/BNF(Bind 'n Fly) drones. If you have never flown/worked with a quadrotor, you can get at RTF/BNF with FPV for under 200$.
Then once you understand the basics your can start to design/build your own.
No one saves money building their own drones. And as someone how also has over 10 3D Printers don't print your own drone for your firsts.
Bornity
rOtring Rapid Pro 0.7mm. The tip is retractable. I daily carry one.
Bornity
I'm sorry I'm a bit tired and I just realized that's a 3DR ublox LEA-6 GPS module from around 2013(IIRC)
Toss that shit out and buy a ublox M8N GPS Module, it will cost you about $25.
The hardware is so old it's not going to be actively supported. You're going to constantly be finding problems with very few resources b/c very few people are plugging a 2013 GPS into a 2020 FC.
Bornity
Hexsoon EDU-450 V2
Pixhawk Cube Orange+ (Standard Set ADS-B)
Here3+ GPS
SIYI MK15 Smart Transmitter/Receiver w/ Digital Video
(2) 4S 5000mah Li-Po Batteries
Check Irlock and Arrishobby
Bornity
4 pin connection with the dotted lines? That's if you wanted to run a GPS without a compass into that serial port, like say you wanted to run 2 GPS's
Bornity
If you're new, don't worry about the autonomous part. It's very difficult to get mid-to-low end flight controllers that run ardupilot well right now.
1 build does not need to do everything. Get flying and then see if you want to spend enough to do autonomous stuff properly
Bornity
Can you take a picture of the pixhawk from the top? Do you have a battery monitor module? It sounds like you are not powering the pixhawk from the battery
Bornity
Congrats!!!
Bornity
You'll want to go with something ArduPilot based.
Don't buy a cheap flight controller.
It is very hard to find mid-to-low end flight controllers, which someone else mentioned multiple, due to the chip shortage issues. Any Holybro Pixhawk you see in stock is just the base not the full flight controller. If you cannot afford to buy a good flight controller you might need to reconsider this project.
Get a Pixhawk Cube Orange+ for your Flight Controller. IRLock has them in stock. And get a SIYI MK15 Smart Transmitter and Receiver w/ camera for control, telemetry & video. Arrishobby or Rcwing has them.
As others said, ecalc.ch can help to spec motors, Props, electronic speed controllers and batteries.
Feel free to message me if you need more help
Bornity
The Rx/Tx wires are for the GPS UART serial signal.
The SDA/SDL are for the magnetometer(compass) which uses I2C.
You can start by confirming the GPS over uart works.
It sounds like you are running arducopter?
Check out 3M Dual Lock, better than Velcro for batteries. One roll needed, it sticks to itself, put a strip on the battery and a strip in the battery bay. The strap just holds it down while the Dual Lock prevents X&Y translation and Z rotation.